Théo Alessandro Hermann
Scan. Model. Decipher.
Making hidden structure visible.
Research Fellow, MIT Senseable City Lab Rio · MSc Robotics, EPFLResearch: how city form shapes light and air.Practice: making autonomous systems legible.
Speaking Dubai Future Week, 18–21 Nov 2026Favela research
A city that was never drawn.
Favelas are built without plans, and the usual urban measurements assume a street grid that is not there.
Vidigal, Rio de Janeiro · terrain and building footprints
MIT Senseable City Lab Rio
Robotics
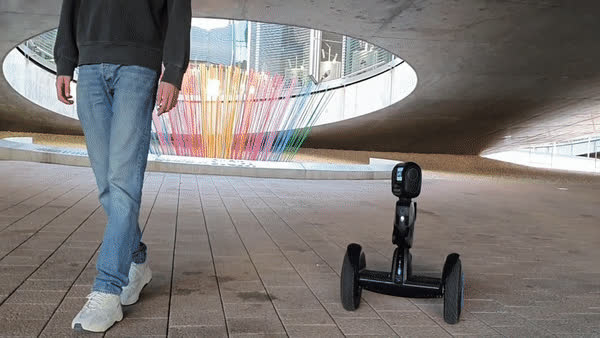
Perception on real robots.
Practice
Making autonomous systems legible
Robot failures the logs don't explain: the real cause, found and proved independently. Agentic systems fail the way robots do.
One example, on a public recording: the robot was in one corridor, and reported, sure to a few centimetres, that it was in another.
More work
I'm Théo, a French-Brazilian roboticist and urban scientist. Paris, São Paulo, Rio, Lausanne, Amsterdam, Barcelona, Stockholm.
I trained in robotics at EPFL, built perception for a person-following robot at VITA Lab and for an autonomous boat at Roboat, then brought the same tools to cities at MIT Senseable City Lab.
Wherever I work, the question is the same: what aren't we seeing yet that explains how the system behaves? Today I help robot makers find out why their systems fail, and I study how city form shapes light and air.
Get in touch.
A project, a collaboration, or a question about the work on this page: write two lines.
thermann.ai@gmail.com